Paris, France
 U.S. citizen
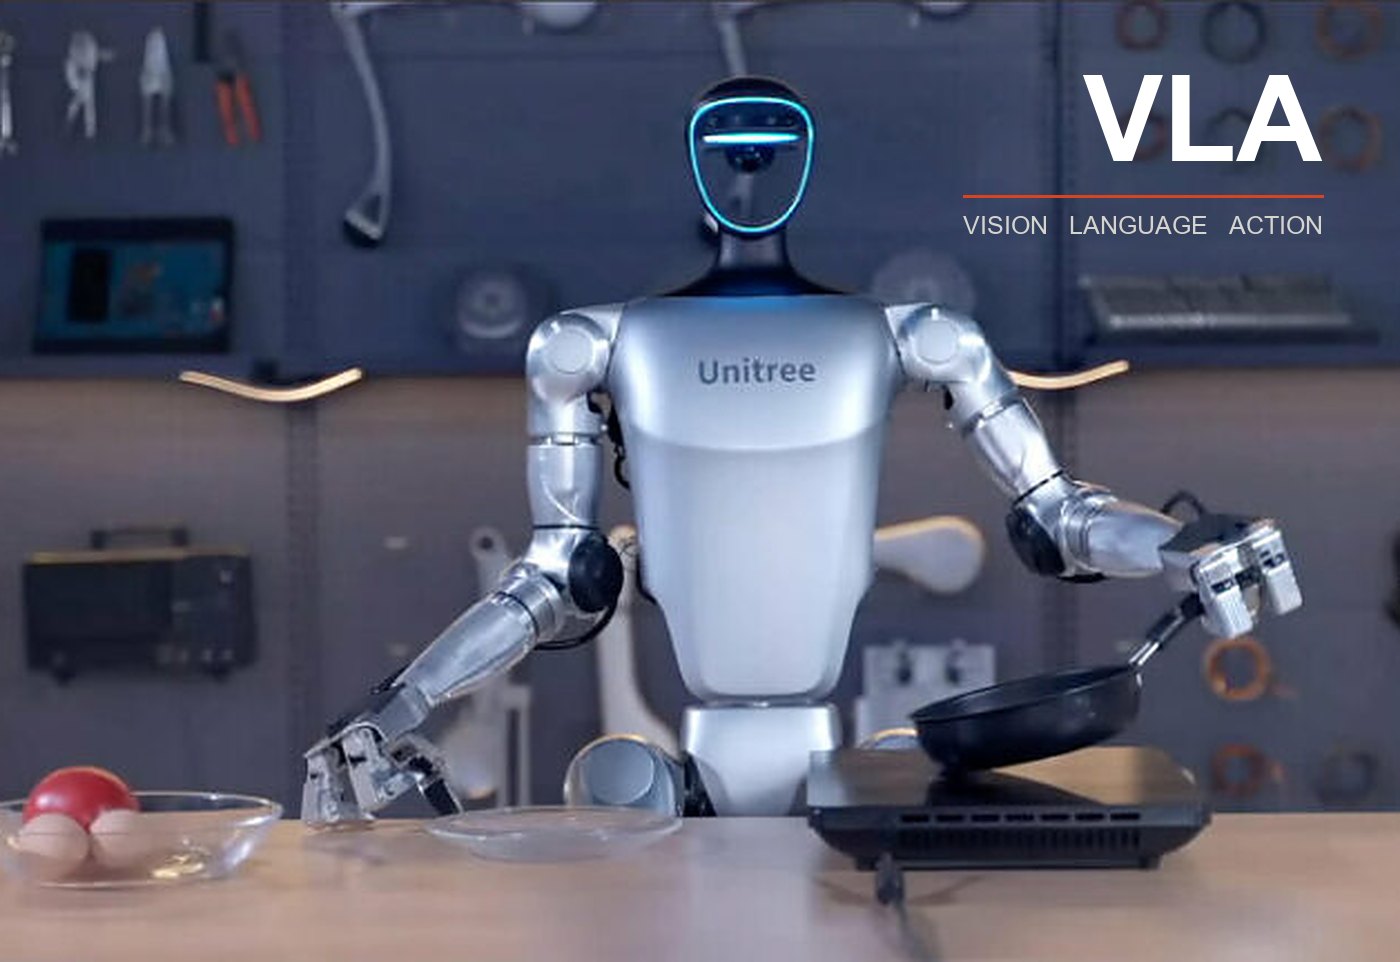
VLA for humanoid home assistance
In progressDesigning, implementing and evaluating an end to end vision language action pipeline that lets a Unitree G1 humanoid carry out household assistance tasks from natural language instructions. Demonstrations are collected by teleoperation with VR and RGB-D cameras, converted into a common VLA training format and used to fine tune open models such as Pi0 and Pi0.5. The work is aimed at safe, reliable execution on the real robot with a person nearby, measured on success rate, robustness, generalisation and how often a human has to step in.